Notes about open source software, computers, other stuff.

Tag: hardware (Page 1 of 2)

Review of 9 months with the Dygma Raise 2 split keyboard

20260115_154245.jpg

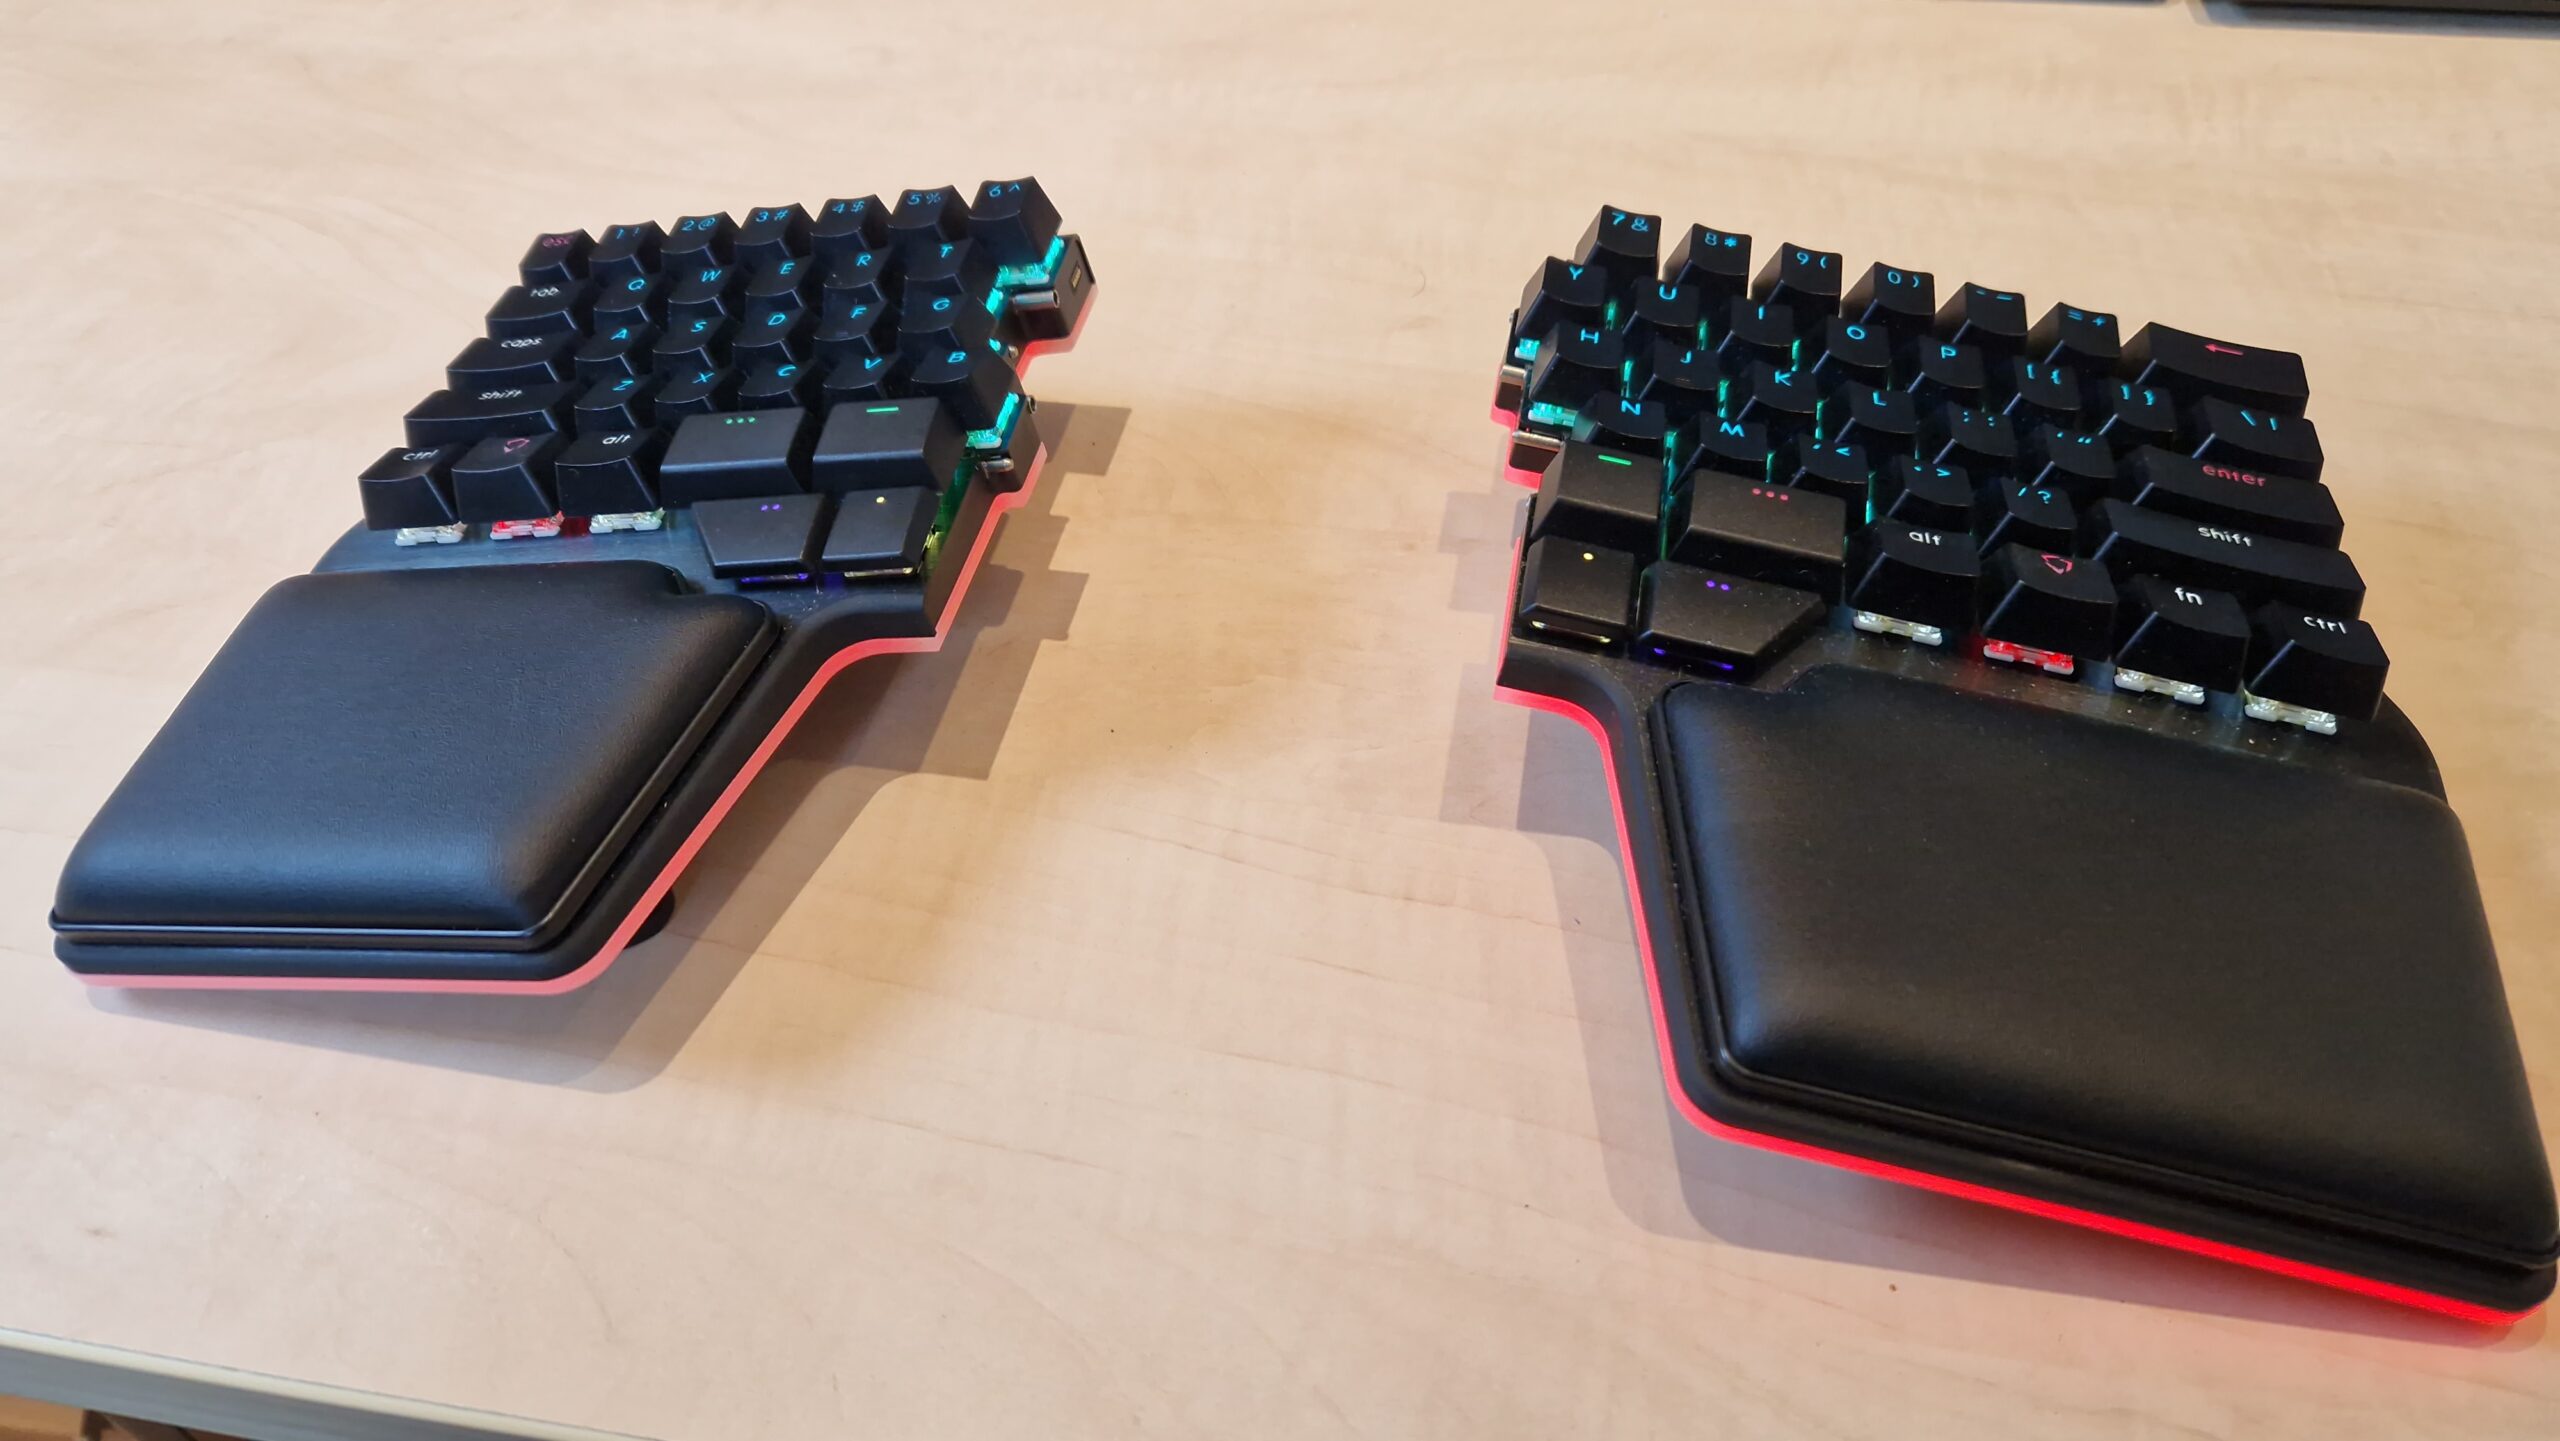
Back in November of 2025, I bought a Dygma Raise 2 split keyboard. I had been thinking about buying some kind of split keyboard for some time, but never bought one for several reasons: first of all, my Das 4 mechanical keyboard was (and is) still going strong. Second, they tend to be pretty expensive, and, third, I was a bit hesitant because most have fewer keys than a regular full-sized keyboard and/or have keys in different places, all of which require me to relearn my typing habits.

I started looking into it again in late 2025, when I was looking for a birthday present. I came across Dygma, a Spanish company, that offered two types of highly customisable keyboards, the Defy and the Raise 2. The latter seemed most attractive because it didn’t have a columnar layout, so I expected the learning curve to be less steep. After some more research I ended up buying one, with the wireless option, the tenting option and underglow. Basically the full package.

Fast forward to yesterday, when a colleague asked me about it. She was interested in getting one because she likes having her mouse right in front of her and currently has it on a lower level of the desk she uses. I started writing some pros and cons, but the text grew larger and larger, so I decided to reproduce it here, where it can maybe be of use to more people.

I have been using it since November 2025 as my daily keyboard. A summary of my experience so far:

  • You really have to put the mouse between the two halves. I first had it to the right of the keyboard, with the two halves at shoulder width, but in that case, reaching the mouse (a trackball in my case) meant overextending the lower arm to the right. This soon led to pain in the upper arm and elbow. Like you said: it turns out to be quite comfortable to have the mouse in between the halves.
  • Knowing how to touch type properly will be very helpful. I apparently needed to relearn some keys because initially, when I tried to hit an h or y I used my left hand. Which meant my finger hit “air”.
  • Be aware of the way the keys are laid out: some keyboards have them “the regular way”, i.e. the rows are slightly shifted horizontally compared to each other. As a result, the q is not right above the a (on a US layout), but slightly to the right of it. The alternative is a column layout where each row is straight above the other, i.e. the columns of keys are straight (but the rows may be misaligned). See for example the Dygma Defy keyboard. I was too afraid I’d have to relearn how to type to by a keyboard with a columnar layout.
  • Most split keyboards are “reduced” in the sense that they don’t have F-keys, nor arrows/pgUp/pgDn/home keys. Note that on my keyboard, the ` and ~ are missing too (the missing backtick is frustrating when writing markdown). Instead they tend to use layers that can be accessed via a modifier key (usually near the thumbs). Do not underestimate the effort to relearn your habits. An example: I was already quite comfortable with the Emacs movement shortcuts (C-p for up, C-f for right, etc.) and have configured LibreOffice and Firefox to also implement those as much as possible). This means that I often don’t need to go into the 2nd layer where my arrows and PgUp/Dn live. However… GitLab, for example uses C-b (back; right arrow) to insert two sets of ** for bold and I can’t seem to disable that. I very often still need to look at my keyboard to make sure I get the arrow keys right. Org mode shortcuts like M-S-arrow up to move a heading up become more involved because it’s not only Alt and Shift, but now also the modifier key for the arrows. I guess this last one is mostly a problem for Emacs users. Not that many other computer tools have shortcuts with that many keys. On the other hand, my 3rd layer contains the media playback keys and for some reason those became ingrained in my spine very easily.
  • If you decide on a keyboard with layers, I like it that mine also has LEDs in the keys so you get a visual confirmation of the layer you are in.
  • My keyboard also has a “tenting” option that allows you to angle the halves upwards (so that your palms are pointing a bit more towards each other). I find a 10° angle to be comfortable. However, I don’t think this a strict requirement. It’s a nice to have.
  • For a keyboard with layers, the configuration software is very important. Dygma’s Bazecor tool is solid. It works under Linux without any issues, gets regular updates, can flash the keyboard’s firmware and is easy to use for defining the layers. To get an idea of the options, you can download it and configure a virtual keyboard.
  • Mechanically, it is a great keyboard. No complaints. Sturdy, pleasant keys, similar to my previous regular mechanical keyboard.
  • Mine also has the option for wireless usage, but I tend not to use that. For one, you have to remember to recharge it, but more importantly, it takes a bit longer to wake up (it goes to sleep after x minutes of not using it to save battery life) and I found that to be annoying.
  • The built-in palm rests are great. Very comfortable.
  • Dygma has a 30-day return policy, which is nice, but seems too short to get used to a keyboard and make a proper decision.

Am I happy with it?

Yes, I’m happy with it, but I’m still missing my separate arrow keys. I (think that I) am as fast as I was before with regular typing, but having to use the 2nd layer for arrows and PgUp/PgDn hasn’t fully settled in yet (actually, maybe that is because I can get away with the Emacs movement keys in most cases).

For these last blocks of text I took my previous Das 4 out of storage again to see if I can still go back to it, and to do a proper comparison with the Dygma. And, yes, that works fine. I notice the typing is a bit less comfortable (in terms of positioning my hands), and the keys seem closer to each other, a bit more crowded. Oh, my wrong hand just typed the h. But moving my right hand to and from the arrow keys is as natural and fast as it was before. I guess that part of the discomfort there comes from the fact that regular arrow (and number pad keys) are in a columnar arrangement, whereas on the Dygma Raise their function is taken over by the regular keys ( e.g. the arrows are [, ], \ and +/= on the right side and, additionally, by s, d, f and e on the left side), which are staggered. Similarly, I can still easily type on my laptop keyboard (although I then miss some of the thumb keys of the Raise 2).

Is it worth the price?

Not sure. It was very, very expensive for a keyboard (around €600 with all the options). I bought it as a company expense, so I saved on taxes, but I don’t think I could have justified the expense if I had to pay it from my regular income/salary. I already thought my previous one (a Das 4) was expensive (IIRC just above €200), but that was a good investment compared to its Logitech predecessor (which wasn’t a mechanical keyboard). I did need a separate palm/wrist pad for it.

Would I buy it again?

Probably. The split design feels more comfortable on the shoulders and the tenting option is another bit of comfort. The layered approach is powerful (maybe I’ll need to spend a bit more time on it to see if I can iron out my arrow key issues), and I like it for the media keys and some other shortcuts. The fact that you don’t need to move your hands to the side is more comfortable and less intruding on the typing workflow.

Now my big question is: should I try a split keyboard with columnar layout… E.g. a refurbished Dygma Defy without all the bells and whistles and try it for 29 days… I guess not, I fear the learning curve is too much without the regular keys/key sizes for enter, backspace, shift…
Related Images:

Getting SMART information from a Seagate Expansion Portable drive

A couple of days ago, I bought myself a 5TB Seagate Expansion Portable drive. This is an 2.5″ external spinning hard disk that connects over USB. In a review on a well-known Dutch website for IT enthusiasts, I read that inside, the drive consists of an ST5000LM000 hard drive and a USB to SATA chip (in contrast to other manufacturers like WD that solder the USB connector directly on the drives circuit board).

After connecting the drive to my computer (that currently runs Ubuntu 21.10), I wanted to see what I could learn about the drive in terms of SMART information. So I tried:

$ sudo smartctl -a /dev/sda
smartctl 7.2 2020-12-30 r5155 [x86_64-linux-5.13.0-41-generic] (local build)
Copyright (C) 2002-20, Bruce Allen, Christian Franke, www.smartmontools.org

Read Device Identity failed: scsi error unsupported field in scsi command

A mandatory SMART command failed: exiting. To continue, add one or more '-T permissive' options.

Trying the suggested -T option didn’t help. So I played around with the -d option that I had used before trying to connect to hard drives behind RAID controllers. That looked better:

$ sudo smartctl -a /dev/sda -T conservative -d sat,auto
smartctl 7.2 2020-12-30 r5155 [x86_64-linux-5.13.0-41-generic] (local build)
Copyright (C) 2002-20, Bruce Allen, Christian Franke, www.smartmontools.org

=== START OF INFORMATION SECTION ===
Vendor:               Seagate
Product:              Expansion HDD
Revision:             1901
Compliance:           SPC-4
User Capacity:        5.000.981.077.504 bytes [5,00 TB]
Logical block size:   512 bytes
Physical block size:  4096 bytes
LU is fully provisioned
Logical Unit id:      0x3e41434334313346
Serial number:        00000000NACC413F
Device type:          disk
Local Time is:        Thu May 19 21:54:04 2022 CEST
SMART support is:     Unavailable - device lacks SMART capability.

=== START OF READ SMART DATA SECTION ===
Current Drive Temperature:     0 C
Drive Trip Temperature:        0 C

Error Counter logging not supported

No Self-tests have been logged

The drive reports the correct size, but also says there is not SMART support. In fact, using -d scsi gave identical output. Because there should only be this USB to SATA translation layer I thought that somehow I should be able to get the SMART commands to work. Looking through the smartmontools website, I came across this article that explains the “SAT with UAS” situation. It seems that the high speed UAS driver disables SAT transfers in certain cases. The workaround is to tell the kernel to use the older usb-storage driver instead of the uas driver. With the lsusb command I identified the manufacturer and device ID of the drive:

$ lsusb | grep -i seagate
Bus 004 Device 012: ID 0bc2:2037 Seagate RSS LLC Expansion HDD

Next, I made sure to unmount and disconnect the drive and then instructed the kernel to use the old driver for this device:

$ echo "0x0bc2:0x2037:u" | sudo tee /sys/module/usb_storage/parameters/quirks

and reconnected the drive. I verified in the kernel logs that the usb-storage driver was indeed used:

mei 19 22:08:30 barabas kernel: usb 4-3.3: new SuperSpeed USB device number 12 using xhci_hcd
mei 19 22:08:30 barabas mtp-probe[983206]: checking bus 4, device 12: "/sys/devices/pci0000:00/0000:00:08.1/0000:0c:00.3/usb4/4-3/4-3.3"
mei 19 22:08:30 barabas mtp-probe[983206]: bus: 4, device: 12 was not an MTP device
mei 19 22:08:30 barabas kernel: usb 4-3.3: New USB device found, idVendor=0bc2, idProduct=2037, bcdDevice=19.01
mei 19 22:08:30 barabas kernel: usb 4-3.3: New USB device strings: Mfr=1, Product=2, SerialNumber=3
mei 19 22:08:30 barabas kernel: usb 4-3.3: Product: Expansion HDD
mei 19 22:08:30 barabas kernel: usb 4-3.3: Manufacturer: Seagate
mei 19 22:08:30 barabas kernel: usb 4-3.3: SerialNumber: 00000000NACC413F
mei 19 22:08:30 barabas kernel: usb 4-3.3: UAS is ignored for this device, using usb-storage instead
mei 19 22:08:30 barabas kernel: usb-storage 4-3.3:1.0: USB Mass Storage device detected
mei 19 22:08:30 barabas kernel: usb-storage 4-3.3:1.0: Quirks match for vid 0bc2 pid 2037: 800000
mei 19 22:08:30 barabas kernel: scsi host6: usb-storage 4-3.3:1.0

Notice the “UAS is ignored” message. And lo and behold, smartctl now works and shows all relevant information:

$ sudo smartctl -a /dev/sda
smartctl 7.2 2020-12-30 r5155 [x86_64-linux-5.13.0-41-generic] (local build)
Copyright (C) 2002-20, Bruce Allen, Christian Franke, www.smartmontools.org

=== START OF INFORMATION SECTION ===
Model Family:     Seagate Barracuda 2.5 5400
Device Model:     ST5000LM000-2U8170
Serial Number:    WCJ6AG24
LU WWN Device Id: 5 000c50 0e0939684
Firmware Version: 0001
User Capacity:    5.000.981.078.016 bytes [5,00 TB]
Sector Sizes:     512 bytes logical, 4096 bytes physical
Rotation Rate:    5400 rpm
Form Factor:      2.5 inches
Device is:        In smartctl database [for details use: -P show]
ATA Version is:   ACS-3 T13/2161-D revision 3b
SATA Version is:  SATA 3.1, 6.0 Gb/s (current: 6.0 Gb/s)
Local Time is:    Thu May 19 22:30:52 2022 CEST
SMART support is: Available - device has SMART capability.
SMART support is: Enabled

=== START OF READ SMART DATA SECTION ===
SMART overall-health self-assessment test result: PASSED

General SMART Values:
Offline data collection status:  (0x00)	Offline data collection activity
					was never started.
					Auto Offline Data Collection: Disabled.
Self-test execution status:      (   0)	The previous self-test routine completed
					without error or no self-test has ever
					been run.
Total time to complete Offline
data collection: 		(    0) seconds.
Offline data collection
capabilities: 			 (0x71) SMART execute Offline immediate.
					No Auto Offline data collection support.
					Suspend Offline collection upon new
					command.
					No Offline surface scan supported.
					Self-test supported.
					Conveyance Self-test supported.
					Selective Self-test supported.
SMART capabilities:            (0x0003)	Saves SMART data before entering
					power-saving mode.
					Supports SMART auto save timer.
Error logging capability:        (0x01)	Error logging supported.
					General Purpose Logging supported.
Short self-test routine
recommended polling time: 	 (   1) minutes.
Extended self-test routine
recommended polling time: 	 ( 827) minutes.
Conveyance self-test routine
recommended polling time: 	 (   2) minutes.
SCT capabilities: 	       (0x7035)	SCT Status supported.
					SCT Feature Control supported.
					SCT Data Table supported.

SMART Attributes Data Structure revision number: 10
Vendor Specific SMART Attributes with Thresholds:
ID# ATTRIBUTE_NAME          FLAG     VALUE WORST THRESH TYPE      UPDATED  WHEN_FAILED RAW_VALUE
  1 Raw_Read_Error_Rate     0x000f   067   065   006    Pre-fail  Always       -       5367808
  3 Spin_Up_Time            0x0003   100   100   000    Pre-fail  Always       -       0
  4 Start_Stop_Count        0x0032   100   100   020    Old_age   Always       -       10
  5 Reallocated_Sector_Ct   0x0033   100   100   036    Pre-fail  Always       -       0
  7 Seek_Error_Rate         0x000f   100   253   045    Pre-fail  Always       -       3765
  9 Power_On_Hours          0x0032   100   100   000    Old_age   Always       -       0 (86 255 0)
 10 Spin_Retry_Count        0x0013   100   100   097    Pre-fail  Always       -       0
 12 Power_Cycle_Count       0x0032   100   100   020    Old_age   Always       -       9
184 End-to-End_Error        0x0032   100   100   099    Old_age   Always       -       0
187 Reported_Uncorrect      0x0032   100   100   000    Old_age   Always       -       0
188 Command_Timeout         0x0032   100   100   000    Old_age   Always       -       0
189 High_Fly_Writes         0x003a   100   100   000    Old_age   Always       -       0
190 Airflow_Temperature_Cel 0x0022   069   069   040    Old_age   Always       -       31 (Min/Max 29/31)
191 G-Sense_Error_Rate      0x0032   100   100   000    Old_age   Always       -       0
192 Power-Off_Retract_Count 0x0032   100   100   000    Old_age   Always       -       2
193 Load_Cycle_Count        0x0032   100   100   000    Old_age   Always       -       23
194 Temperature_Celsius     0x0022   031   040   000    Old_age   Always       -       31 (0 19 0 0 0)
197 Current_Pending_Sector  0x0012   100   100   000    Old_age   Always       -       0
198 Offline_Uncorrectable   0x0010   100   100   000    Old_age   Offline      -       0
199 UDMA_CRC_Error_Count    0x003e   200   200   000    Old_age   Always       -       0
240 Head_Flying_Hours       0x0000   100   253   000    Old_age   Offline      -       0 (7 164 0)
241 Total_LBAs_Written      0x0000   100   253   000    Old_age   Offline      -       1723222
242 Total_LBAs_Read         0x0000   100   253   000    Old_age   Offline      -       3644586

SMART Error Log Version: 1
No Errors Logged

SMART Self-test log structure revision number 1
No self-tests have been logged.  [To run self-tests, use: smartctl -t]

SMART Selective self-test log data structure revision number 1
 SPAN  MIN_LBA  MAX_LBA  CURRENT_TEST_STATUS
    1        0        0  Not_testing
    2        0        0  Not_testing
    3        0        0  Not_testing
    4        0        0  Not_testing
    5        0        0  Not_testing
Selective self-test flags (0x0):
  After scanning selected spans, do NOT read-scan remainder of disk.
If Selective self-test is pending on power-up, resume after 0 minute delay.

Now that I know how to do this, let’s undo the “use usb-storage driver instead of the uas driver” (alternatively, a reboot should also work, but who wants that?):

$ echo "" | sudo tee /sys/module/usb_storage/parameters/quirks

I will use this drive as a backup drive while I am travelling, so the aim of this post is not only to inform you as my reader(s), but also to remind my future self of how I did this. Now I only need to remember to check the SMART values every once in a while :-).

Related Images:

Using the Lenovo Thunderbolt 3 Essential Dock with Linux

Today the Lenovo Thunderbolt 3 Essential dock I had ordered just before the new year arrived. My current laptop is a 6th Gen Lenovo Thinkpad X1 Carbon, which actually has two Tunderbolt 3 (TB3) ports. For a while the cable mess on my desk had been bothering me and a dock looked like a good way to get rid of both the clutter and the fact that I had to plug in a power cable, an HDMI cable, a USB cable and a network cable. The latter was especially tricky, because my laptop doesn’t have a dedicated ethernet port, but instead has a dongle that plugs into one of the TB3 ports. Of course, I didn’t want it to happen that I was on the road without the dongle, so double checking and making sure I had it in my bag was a regular worry.

With the TB3 Essential dock all this should be over. The dock is pretty well equipped:

  • 1 ethernet port (1Gbps)
  • 1 HDMI 2.0 port
  • 1 DisplayPort 1.4
  • 2 USB A 3.0 1.5Gbps ports
  • 2 USB C 10Gbps ports (no video support)
  • 1 3.5 mm audio jack.

The one thing that remained to be seen, of course, was whether the all those ports would work under Linux as well. I read some promising reports for other TB3-based docks from Lenovo, so I decided to order it.

After connecting the various cables to the dock came the moment supreme: I plugged in the TB3 cable to the laptop. And… The display connected to the HDMI port lit up. So far, so good! No USB functionality, however. Time to dive into the BIOS, because I remembered having seen some settings there, including some security related ones.

In the BIOS I couldn’t change the TB3 security setting because, as the help message explained, the graphics memory was set to 512MB. I’m not sure why this is an issue, but I looked up the graphics RAM setting and reduced it to 256MB. Next, I went back to the TB settings and set the security level to the first option: “No security”, followed by a reboot. Now, everything worked. That is one step in the right direction.

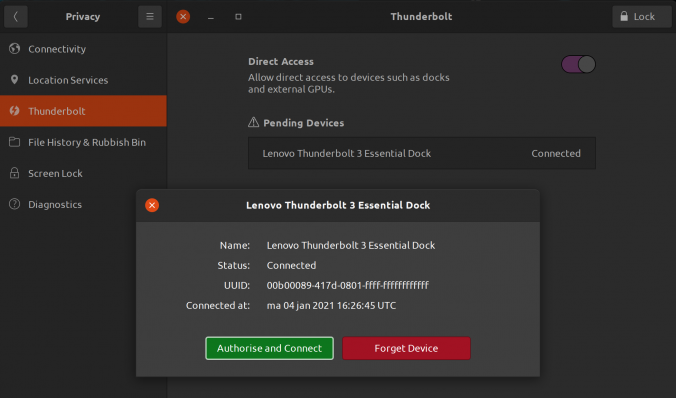
However, I wasn’t willing to forgo all security, so I went back to the BIOS settings and set the security level to “Secure Connection” (according to this blog post at dell.com this is security level 2 or SL2). I rebooted and indeed, no USB. So I went to Ubuntu’s Thunderbolt settings and there I had to press the ‘Unlock’ button in the top right corner, after which I could click on a button authorise the dock. After that all connections worked again. From the commandline, the boltctl utility can be used to see more information on the connected thunderbolt devices. This is the output for an unauthorised device:

$ boltctl list
? Lenovo Thunderbolt 3 Essential Dock
  ?? type:          peripheral
  ?? name:          Thunderbolt 3 Essential Dock
  ?? vendor:        Lenovo
  ?? uuid:          00b00089-417d-0801-ffff-ffffffffffff
  ?? status:        connected
  ?  ?? domain:     ca030000-0070-6f08-2382-4312b0238921
  ?  ?? authflags:  none
  ?? connected:     ma 04 jan 2021 16:26:45 UTC
  ?? stored:        ma 04 jan 2021 16:20:57 UTC
     ?? policy:     iommu
     ?? key:        no

And this is the output after clicking the “Authorise” button in the Ubuntu settings:

? boltctl list
? Lenovo Thunderbolt 3 Essential Dock
  ?? type:          peripheral
  ?? name:          Thunderbolt 3 Essential Dock
  ?? vendor:        Lenovo
  ?? uuid:          00b00089-417d-0801-ffff-ffffffffffff
  ?? status:        authorized
  ?  ?? domain:     ca030000-0070-6f08-2382-4312b0238921
  ?  ?? authflags:  none
  ?? authorized:    ma 04 jan 2021 16:30:07 UTC
  ?? connected:     ma 04 jan 2021 16:26:45 UTC
  ?? stored:        ma 04 jan 2021 16:20:57 UTC
     ?? policy:     iommu
     ?? key:        yes (new)

Nice!

However, my joy was shortlived, because after disconnecting and reconnecting the dock, the USB ports had stopped working again. The device had to be authorised again. This seemed tedious, so I set about reading more in the boltctl man page and found that there was a way to enroll a device permanently. So that is what I did. First I removed its UUID from the database:

$ boltctl forget 00b00089-417d-0801-ffff-ffffffffffff

And then added it again, this time with the auto policy:

$ boltctl enroll --policy auto 00b00089-417d-0801-ffff-ffffffffffff
 ? Lenovo Thunderbolt 3 Essential Dock
   ?? type:          peripheral
   ?? name:          Thunderbolt 3 Essential Dock
   ?? vendor:        Lenovo
   ?? uuid:          00b00089-417d-0801-ffff-ffffffffffff
   ?? dbus path:     /org/freedesktop/bolt/devices/00b00089_417d_0801_ffff_ffffffffffff
   ?? status:        authorized
   ?  ?? domain:     ca030000-0070-6f08-2382-4312b0238921
   ?  ?? parent:     ca030000-0070-6f08-2382-4312b0238921
   ?  ?? syspath:    /sys/devices/pci0000:00/0000:00:1d.0/0000:05:00.0/0000:06:00.0/0000:07:00.0/domain0/0-0/0-1
   ?  ?? authflags:  secure
   ?? authorized:    ma 04 jan 2021 22:33:08 UTC
   ?? connected:     ma 04 jan 2021 22:32:43 UTC
   ?? stored:        ma 04 jan 2021 16:20:57 UTC
      ?? policy:     auto
      ?? key:        yes

As you can see from the boltctl list output below, the policy is now set to auto (instead of the previous iommu):

$ boltctl list
 ? Lenovo Thunderbolt 3 Essential Dock
   ?? type:          peripheral
   ?? name:          Thunderbolt 3 Essential Dock
   ?? vendor:        Lenovo
   ?? uuid:          00b00089-417d-0801-ffff-ffffffffffff
   ?? status:        authorized
   ?  ?? domain:     ca030000-0070-6f08-2382-4312b0238921
   ?  ?? authflags:  secure
   ?? authorized:    ma 04 jan 2021 22:41:46 UTC
   ?? connected:     ma 04 jan 2021 22:41:45 UTC
   ?? stored:        ma 04 jan 2021 16:20:57 UTC
      ?? policy:     auto
      ?? key:        yes

Now I can disconnect and reconnect the dock without problems :-).

I also tested the 3.5mm audio port, which worked (at least for listening, I didn’t have a headset with microphone at hand). Same for the two USB A and the two USB C ports. Finally, I tested the DisplayPort and that worked too. In fact, connecting my 3440×1440 screen via both HDMI and DP to the dock worked fine. The Ubuntu display settings showed a “3 monitor” setup, two 3440×1440 screens and the latop’s own screen at 2560×1440.

So, in conclusion: the Lenovo Thunderbolt 3 Essential dock is fully supported under Ubuntu 20.04.

Thanks to this blog post at FunnelFiasco.com for pointing me to the boltctl utility!

Related Images:

Shucking hard drives

I recently bought several external hard drives. After looking around on the Internet a bit I settled for Seagate Expansion Desktop (v2) drives. I had read about these drives before and according to the internet the 10TB and larger drives have very interesting drives inside. In fact, I recently bought two 10TB versions of this drive, which contained Barracuda Pro drives (ST10000DM004). These drives are rated for 24hr/day usage, and spin at 7200 rpm so they work very well in a small NAS machine I use. At the time of writing these 10TB external drives cost around €193, whereas the bare internal drive itself costs around €290. Quite the difference! This is why people love so-called ‘shucking’: removing the drives from the enclosure and using them in e.g. their home NAS or home server.

For my annual offline backups I bough a Seagate Expansion Desktop (v2) 12TB (part nr. STEB12000400). For this drive things are even better: it contains an IronWolf Pro drive (ST12000NE008). These are true server drives rated for 24×7 use in servers of up to 24 drive bays. In fact, I use 8TB and 10TB IronWolf Pro’s in servers I use for work. Here the price difference is €210 for the external drive (a nice discount in a Dutch web shop recently) vs. €360 for the internal drive.

Of course, warranty can be an issue when shucking drives. I haven’t (yet?) had the need to return one of my shucked drives. I guess I’d have to put them back into the external enclosures. This would be possible, although I didn’t manage to remove the enclosures without damaging the little clamps that kept the lid attached to the rest of the case… But at these price differences I will take the risk (at least for personal use; professionally warranty without hassle may be worth the extra cost).

Related Images:

Fixing backlight control with Ubuntu on my ThinkPad T440s

Some time ago I bought a ThinkPad T440s for work. It’s an amazing machine! Before that I used a ThinkPad X121, which served me very well on my daily commute. This machine was getting a bit old, and given that my new job (more about which in a later post) also requires me to have a better machine with more screen real estate, it was high time to upgrade.

Ubuntu (13.10 and 14.04) runs well on the T440s, only two things didn’t work as expected:

  • The WWAN interface (mobile internet, from Ericsson) seems to connect when I select it in the network manager, but the adaptor seems to disappear almost immediately after that. A few seconds it appears again. [edit 20140514]I just found out that it’s working, probably this was fixed in Ubuntu 14.04[/edit]
  • The screen’s backlight brightness can be reduced/increase using the Fn-F5 and Fn-F6 keys, but only in a weird way: several key presses are needed for one unit of decrease/increase.

This last bug can be fixed by booting with the following kernel argument:

  acpi_backlight=vendor

Simply add this to the GRUB_CMDLINE_LINUX_DEFAULT line in /etc/default/grub:

  GRUB_CMDLINE_LINUX_DEFAULT="acpi_backlight=vendor quiet splash"

and run sudo update-grub. Reboot and you will be able to change the backlight brightness in finer steps.

I found this solution somewhere on the internet a few weeks ago, wrote it down, but can’t remember anymore what the original URL was. My apologies.

Related Images:

Booting an Ubuntu server with a degraded software RAID array

My home server runs Ubuntu 12.04 with a software RAID 5 array and since a couple of days I’ve been getting e-mails from the SMART daemon warning me of uncorrectable errors on one of the drives. Today I took the time to take the failing drive out and check it with the tools from the manufacturer.

Because I didn’t want to run the risk of unplugging the wrong drive with the system on (and thus losing the whole RAID array) I shut the server down, removed the harddrive and started it again. The idea was that it would boot right back into the OS, but with a degraded RAID array. Unfortunately the server didn’t come up… After connecting a keyboard and monitor to it it turned out that the system was waiting with an initramfs prompt. From there I could check that the RAID array was indeed degraded, but functioning fine as I could manually mount all partitions.

Some Googling later I found out that by default Ubuntu doesn’t boot into a degraded software RAID array. This is to make sure you as administrator know something is wrong. A good idea for a laptop or PC, but not for a standalone server. The solution is the following:

  • From the initramfs prompt mount your original filesystems, for example in /mnt.
  • Use chroot /mnt to change root into your server’s hard disks.
  • In the file /etc/initramfs-tools/conf.d/mdadm add or change the line to
    BOOT_DEGRADED=true
    
  • Then run
    update-initramfs -u

    to regenerate the initial ramdisk.

  • Type exit to exit the chroot environment.
  • Unmount your file systems and reboot

Now your server should continue booting even though it has a degraded RAID array.

Links

Related Images:

The Raspberry Pi runs ProbABEL

One of the first things I tried on my Raspberry Pi was to compile ProbABEL and see if it runs. Since the Raspberry Pi has an ARM processor I wasn’t sure whether our code was portable to it. Apparently it is! Compiling ProbABEL (r.1027 from SVN) took 30 minutes (single threaded of course) compared to 34 seconds on my Desktop (4 threads on an Intel Core i3 processor), but hey, it worked :-). Surprisingly it also passed all the checks in make check.

Once I hook up some more storage to device I will try to run ProbABEL on some real data. It will be interesting to see how much time it takes to run a linear regression on e.g. chromosome 22 of HapMap3 imputated data for a few hundred samples…

Will the Raspberry Pi be the next platform for GWAS ;-)?

Related Images:

Enter the Raspberry Pi!

Two weeks ago I received a Raspberry Pi! The Raspberry Pi is a small computer based not on a “regular” Intel or AMD x86 processor, but on an ARM processor (similar to the ones used in smartphones etc.). The one I ordered is a model B (with ethernet) and 512MB RAM.

The idea behind this nifty little computer is to provide kids with a low-cost but fully functional computer with which they could start learning more about programming. I’m not sure if this goal will be widely met, but for me it worked ;-). Having this little machine (with its case it measures roughly 10 x 6 x 2.5 cm) in my hands and installing Raspbian Linux on an SD card and looking at the terminal as it booted reminded me of the times when I first played with Slackware Linux on a 486. Of course Raspbian (well, Linux in general) is much more advanced than Slackware 7.0 back in 1999/2000 but the not too stellar performance of the graphical desktop is somewhat comparable.

Apart from playing around with it I’m not sure yet what I’m going to use it for. A domotica hub? A small web sserver? Use DosBox to play old games (from even before the 486 era)? We’ll see!

By the way, I order mine on Thursday Novermber 8th and on the Tuesday after that the package landed on my doorstep. Amazing after hearing about people waiting for months for their orders to be shipped. I order mine from New IT. It probably cost a little bit more, but who cares :-).

Related Images:

Using Plugwise adapters with Linux

Yesterday I received a small package I had ordered: the Plugwise Home Start kit. According to the box it is an energy management and control system. The idea is that you insert a sort of adaptor between a power socket and a device and using the Plugwise Source software you can monitor the power usage of the device. Furthermore, you can use the software to create schedule to turn the device on and off at a specific time.

The package contains the following:

  • a USB adapter (called the Stick)
  • a Circle+, the master adaptor that keeps track of the other devices in the network
  • a Circle, the regular members of the Plugwise network

The Circles communicate to each other using the ZigBee protocol in the 2.4GHz range. According to the documentation, the range of each Circle is about 5m.

Unfortunately the Source software only runs on windows. Luckily some people have already analysed the protocol and written some software to control the Plugwise devices (see links below).

First steps

Plugging the USB dongle in gives the following output in /var/log/syslog:

Nov 19 12:20:37 barabas kernel: [  182.855742] usb 1-1.6.1.1.3: new full speed USB device number 14 using ehci_hcd
Nov 19 12:20:37 barabas mtp-probe: checking bus 1, device 14: "/sys/devices/pci0000:00/0000:00:1a.0/usb1/1-1/1-1.6/1-1.6.1/1-1.6.1.1/1-1.6.1.1.3"
Nov 19 12:20:37 barabas mtp-probe: bus: 1, device: 14 was not an MTP device
Nov 19 12:20:37 barabas kernel: [  183.169370] usbcore: registered new interface driver usbserial
Nov 19 12:20:37 barabas kernel: [  183.169389] USB Serial support registered for generic
Nov 19 12:20:37 barabas kernel: [  183.169431] usbcore: registered new interface driver usbserial_generic
Nov 19 12:20:37 barabas kernel: [  183.169434] usbserial: USB Serial Driver core
Nov 19 12:20:37 barabas kernel: [  183.171310] USB Serial support registered for FTDI USB Serial Device
Nov 19 12:20:37 barabas kernel: [  183.171552] ftdi_sio 1-1.6.1.1.3:1.0: FTDI USB Serial Device converter detected
Nov 19 12:20:37 barabas kernel: [  183.171588] usb 1-1.6.1.1.3: Detected FT232RL
Nov 19 12:20:37 barabas kernel: [  183.171591] usb 1-1.6.1.1.3: Number of endpoints 2
Nov 19 12:20:37 barabas kernel: [  183.171595] usb 1-1.6.1.1.3: Endpoint 1 MaxPacketSize 64
Nov 19 12:20:37 barabas kernel: [  183.171598] usb 1-1.6.1.1.3: Endpoint 2 MaxPacketSize 64
Nov 19 12:20:37 barabas kernel: [  183.171602] usb 1-1.6.1.1.3: Setting MaxPacketSize 64
Nov 19 12:20:37 barabas kernel: [  183.171975] usb 1-1.6.1.1.3: FTDI USB Serial Device converter now attached to ttyUSB0
Nov 19 12:20:37 barabas kernel: [  183.171998] usbcore: registered new interface driver ftdi_sio
Nov 19 12:20:37 barabas kernel: [  183.172002] ftdi_sio: v1.6.0:USB FTDI Serial Converters Driver
Nov 19 12:20:37 barabas modem-manager[901]: <info>  (ttyUSB0) opening serial port...
Nov 19 12:20:49 barabas modem-manager[901]: <info>  (ttyUSB0) closing serial port...
Nov 19 12:20:49 barabas modem-manager[901]: <info>  (ttyUSB0) serial port closed
Nov 19 12:20:49 barabas modem-manager[901]: <info>  (ttyUSB0) opening serial port...
Nov 19 12:20:55 barabas modem-manager[901]: <info>  (ttyUSB0) closing serial port...
Nov 19 12:20:55 barabas modem-manager[901]: <info>  (ttyUSB0) serial port closed

lsusb gives:

Bus 001 Device 014: ID 0403:6001 Future Technology Devices International, Ltd FT232 USB-Serial (UART) IC

I couldn’t get the pairing to work under Linux (with the PlugwiseOnLinux scripts), Even though I corrected the MAC address in the python code. I then tried it in Windows where I failed at first also. After resetting the Circle+ and the Circle (removing/inserting them into the power outlet with 3 second intervals, as mentioned in the FAW on the plugwise website) I managed to pair the Circles. Looking back, I think I didn’t wait long enough for the pairing to work under Linux. During the trials in Windows I noticed that the pairing can take up to about 5 minutes…

Back in Linux I used python-plugwise (see links below) to turn the Circles on and off, e.g. this is how I turn my Circle+ off (note that I am a member of the dialout group, which is needed to communicate with /dev/ttyUSB0):

$ plugwise_util -d /dev/ttyUSB0 -m 000D6F0000B1C117 -s off

This is what I want! The only minor downside of python-plugwise is that it depends on the crcmod python library, which apparently is not package for Debian/Ubuntu. So installing using the python-setup framework as mentioned in the README is necessary.

Reading out the current power usage of my Circle works also:

$ plugwise_util -d /dev/ttyUSB0 -m 000D6F0000B85134 -p
power usage: 2.27W

So, no that it works, what am I going to do with the Plugwise modules? I’m going to use them in my backup scripts to switch the power to my external hard drives.

Making a .deb

I used checkinstall to make a package of python-plugwise. In a working directory, first check out the source code of python-plugwise using mercurial, as mentioned on the web site:

$ hg clone https://bitbucket.org/hadara/python-plugwise

Then run checkinstall and don’t forget to fill in the details correctly. For example, the package name is ‘python’ by default, which you definitely don’t want, since that would overwrite Ubuntu’s default ‘python’ package. Also make sure that you remove the crcmod python library if you installed python-plugwise before, otherwise it won’t get packaged. The output below shows the final values, after I changed them.

$ sudo checkinstall -D python setup.py install
 
checkinstall 1.6.2, Copyright 2009 Felipe Eduardo Sanchez Diaz Duran
	      This software is released under the GNU GPL.


*****************************************
**** Debian package creation selected ***
*****************************************
 
This package will be built according to these values:
 
0 -  Maintainer: [ lennart@karssen.org ]
1 -  Summary: [ python-plugwise is used to control the Plugwise power switches as well as read out information on power usage. ]
2 -  Name:    [ python-plugwise ]
3 -  Version: [ 0.2-hg-20111120 ]
4 -  Release: [ 1 ]
5 -  License: [ GPL ]
6 -  Group:   [ checkinstall ]
7 -  Architecture: [ amd64 ]
8 -  Source location: [ python-plugwise ]
9 -  Alternate source location: [  ]
10 - Requires: [ python ]
11 - Provides: [ python-plugwise ]
12 - Conflicts: [  ]
13 - Replaces: [  ]
 
Enter a number to change any of them or press ENTER to continue:

You can check the contents of the package to make sure the crcmod
files are included using dpkg:

$ dpkg --contents python-plugwise_0.2-hg-20111120-1_amd64.deb

An idea for later: make an SNMP module that calls plugwise_util to get the power usage so that I can monitor the power usage of a device using Cacti.

Links

Related Images:

BluePad and Ubuntu 11.10

Over the last few years I’ve always used BluePad (the author’s blog, source and packages available at sf.net) when I had to do a presentation. BluePad allows me to use my Nokia 6230i to send PgUp and PgDn signals to my laptop via bluetooth and thus control my presentation without standing next to laptop all the time.

Unfortunately the author hasn’t updates his .deb packages in a long time, so trying to install the BluePad .deb on a recent Debian or Ubuntu machine will fail due to missing dependencies. I work around this issue by installing BluePad only when I need it and removing it afterwards. Here is how to install it.

dpkg -i --force-depends bluepad_0.4_all.deb

In older Ubuntu installations this was enough, but with Ubuntu’s Unity interface replacing Gnome the BluePad icon doesn’t appear in the top menu bar anymore and as a result it isn’t possible anymore to interact with it. So you’ll have no way of connecting the laptop to the phone.

To remedy this use the following command to allow all applications to show up in the system tray:

gsettings set com.canonical.Unity.Panel systray-whitelist "['all']"

Restart Unity or log out and back in to get the changes accepted.

After the presentation is over and the BluePad removed, use this line to reset the system tray settings:

gsettings set com.canonical.Unity.Panel systray-whitelist "['']"

(That’s two single quotes within the brackets).

Related Images:

« Older posts

© 2026 Lennart's weblog

Theme by Anders NorénUp ↑